

Joint Computation Offloading and Power Control Optimization for Task Graph in UAV-Assisted Mobile Edge Computing
-
摘要: 针对无人机协助移动边缘计算系统中边缘智能任务存在图结构特征造成卸载决策相互约束且依序执行效率低下的问题,该文提出了面向任务图的计算卸载与功率控制联合优化策略。首先,将边缘智能任务建模为有向无环图,联合前驱-后继任务依赖关系、卸载决策、功率控制与用户能量预算等约束,构建系统总时延最小化优化问题。其次,考虑到任务图的事件驱动特性和局部观测下的多用户协同决策需求,提出了一种图结构增强的多智能体近端策略优化算法,通过图神经网络提取任务拓扑依赖特征,并在集中训练、分散执行框架下联合优化任务执行顺序、卸载决策和发射功率。仿真结果表明,所提算法相比典型学习类算法和启发式算法能够有效降低系统总时延,并具有较好的收敛性和任务结构适应性。Abstract:
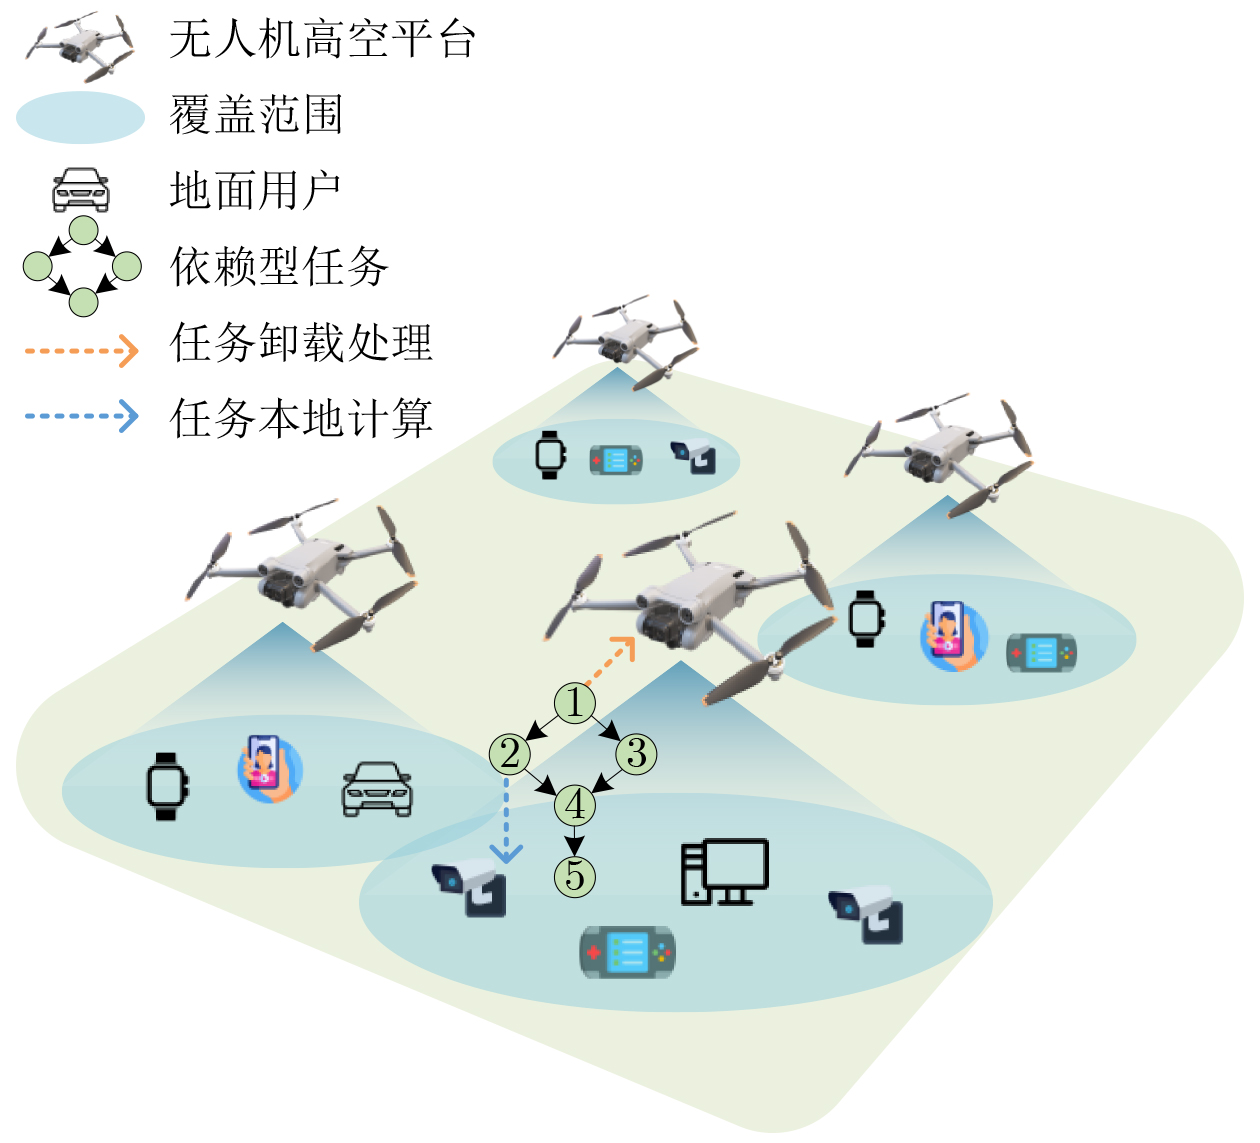
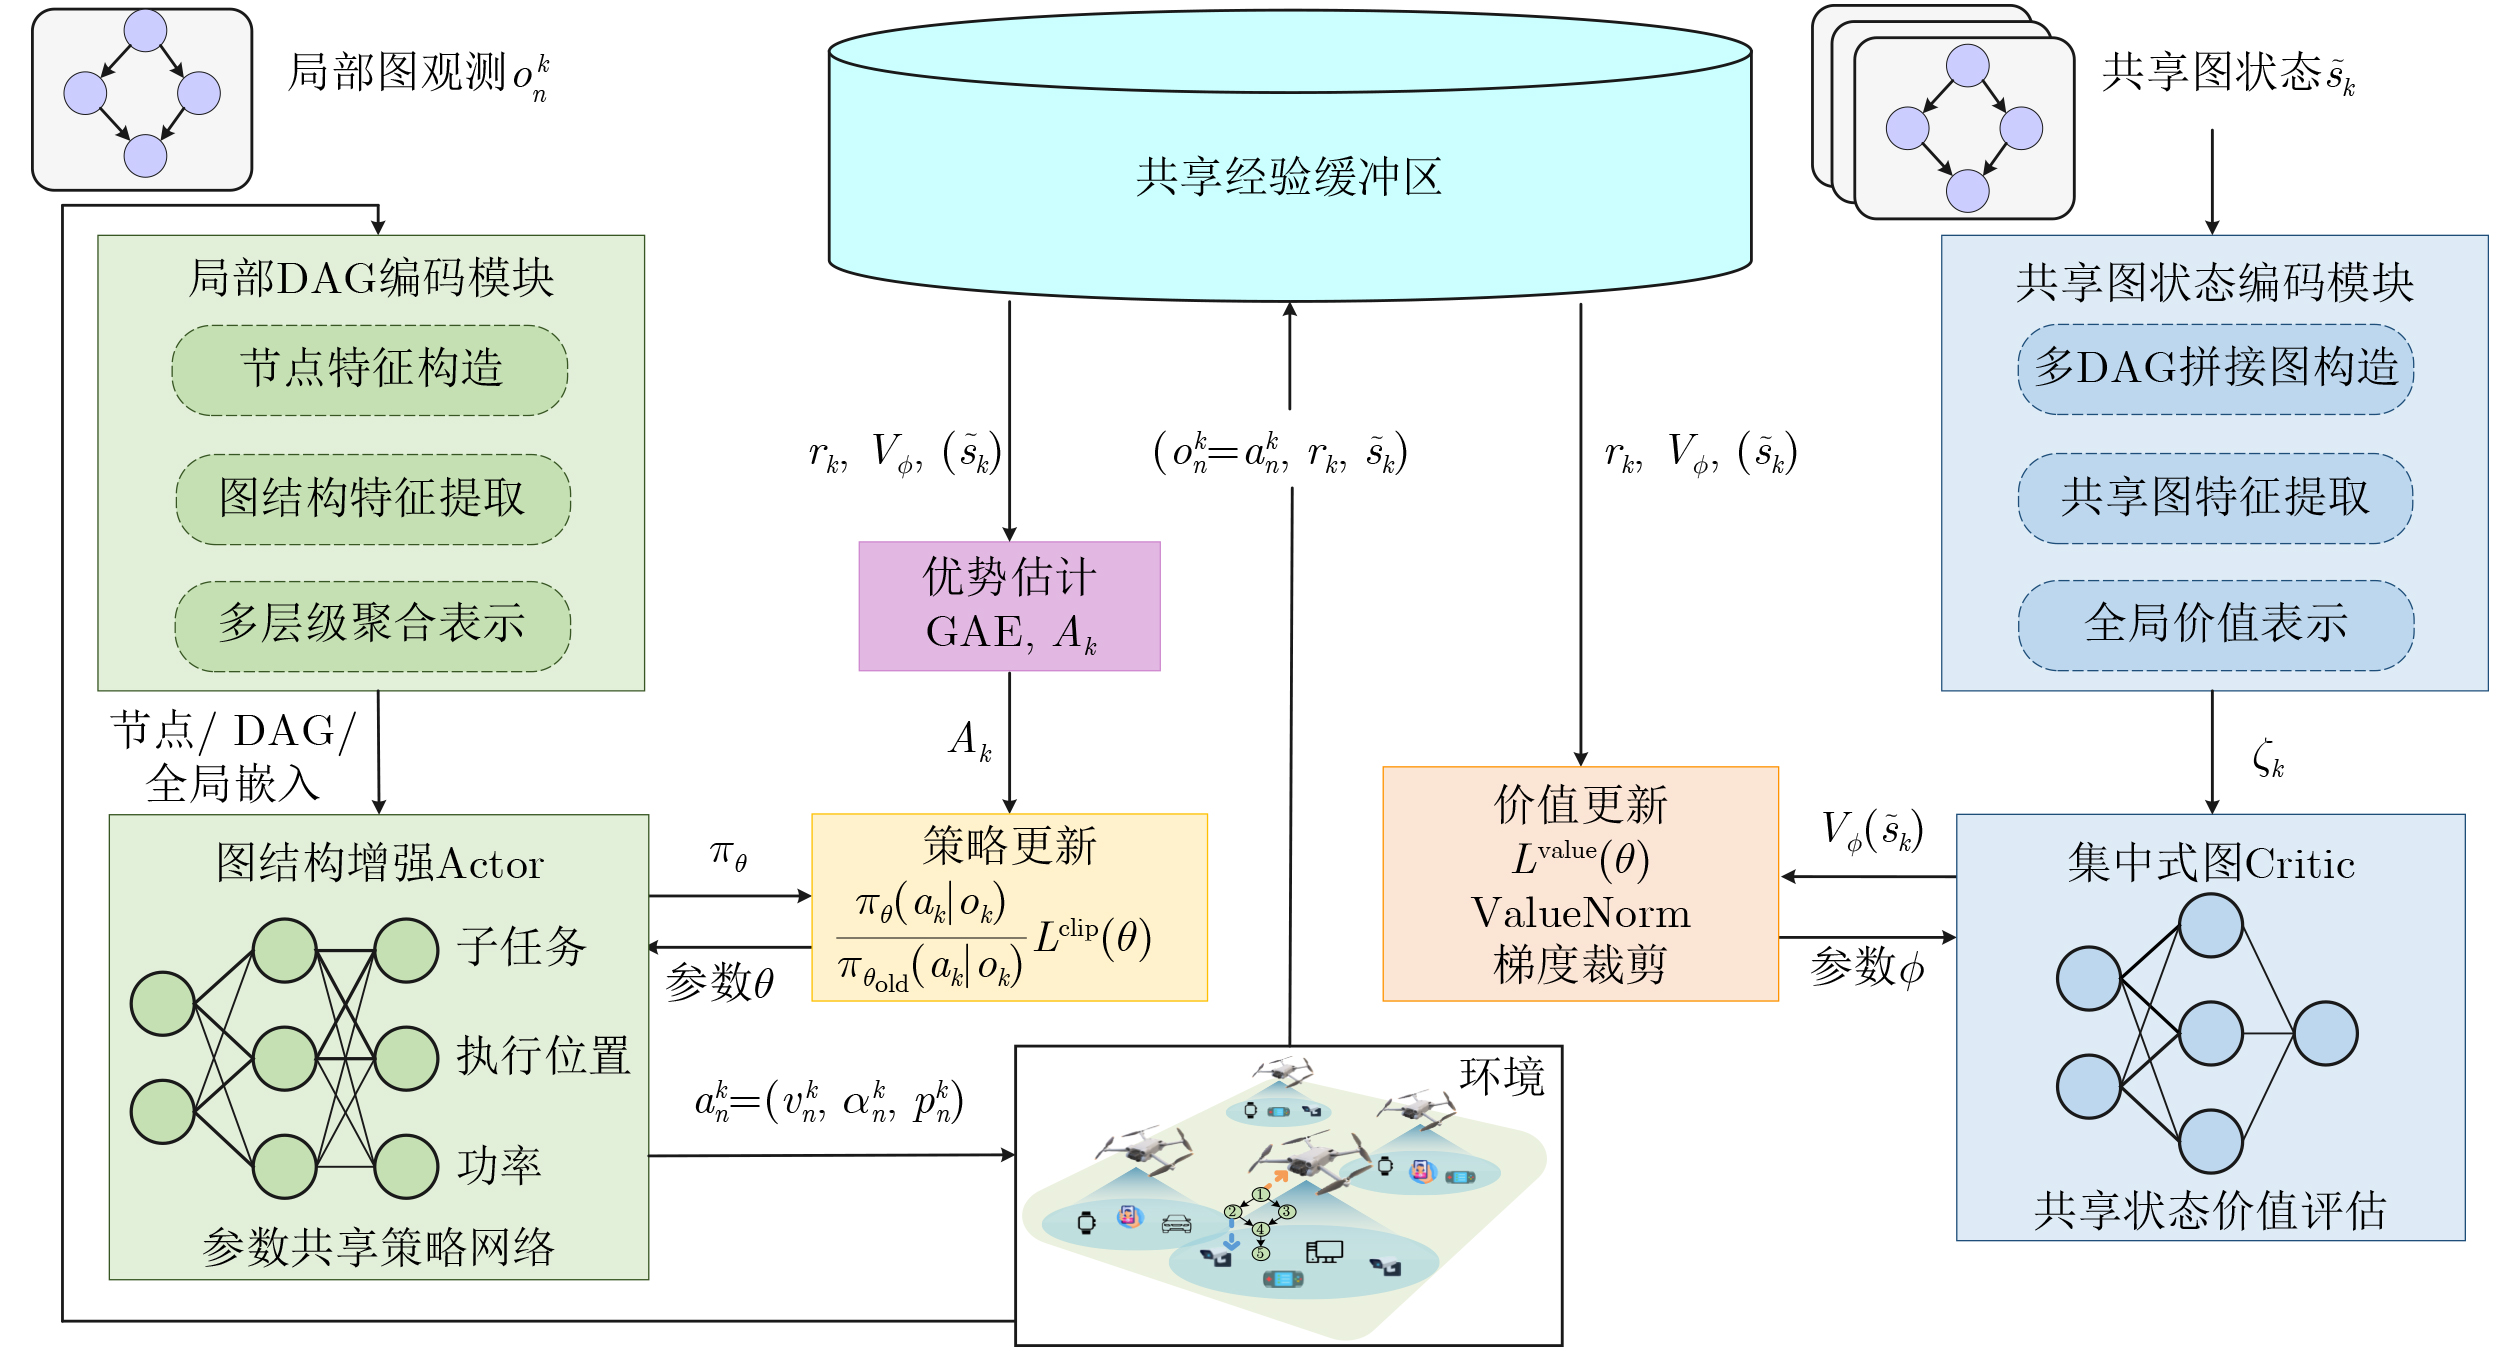
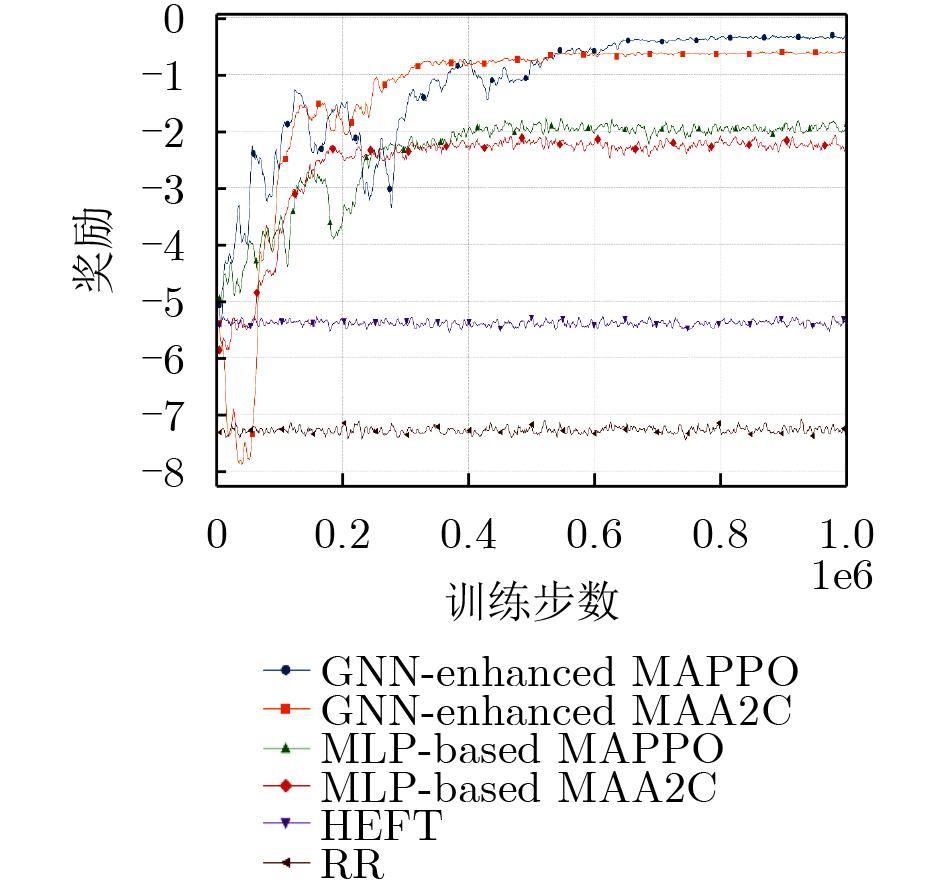
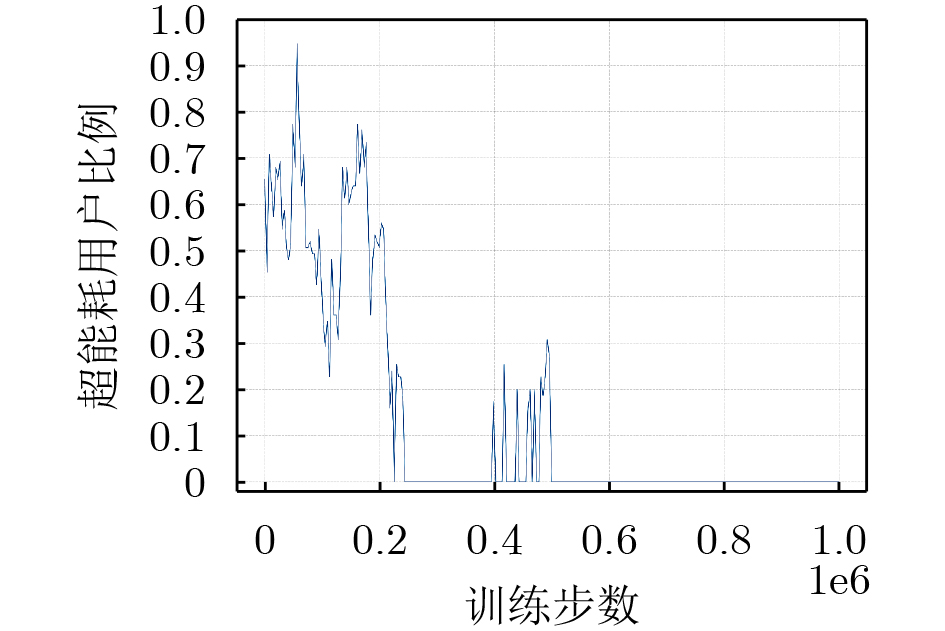
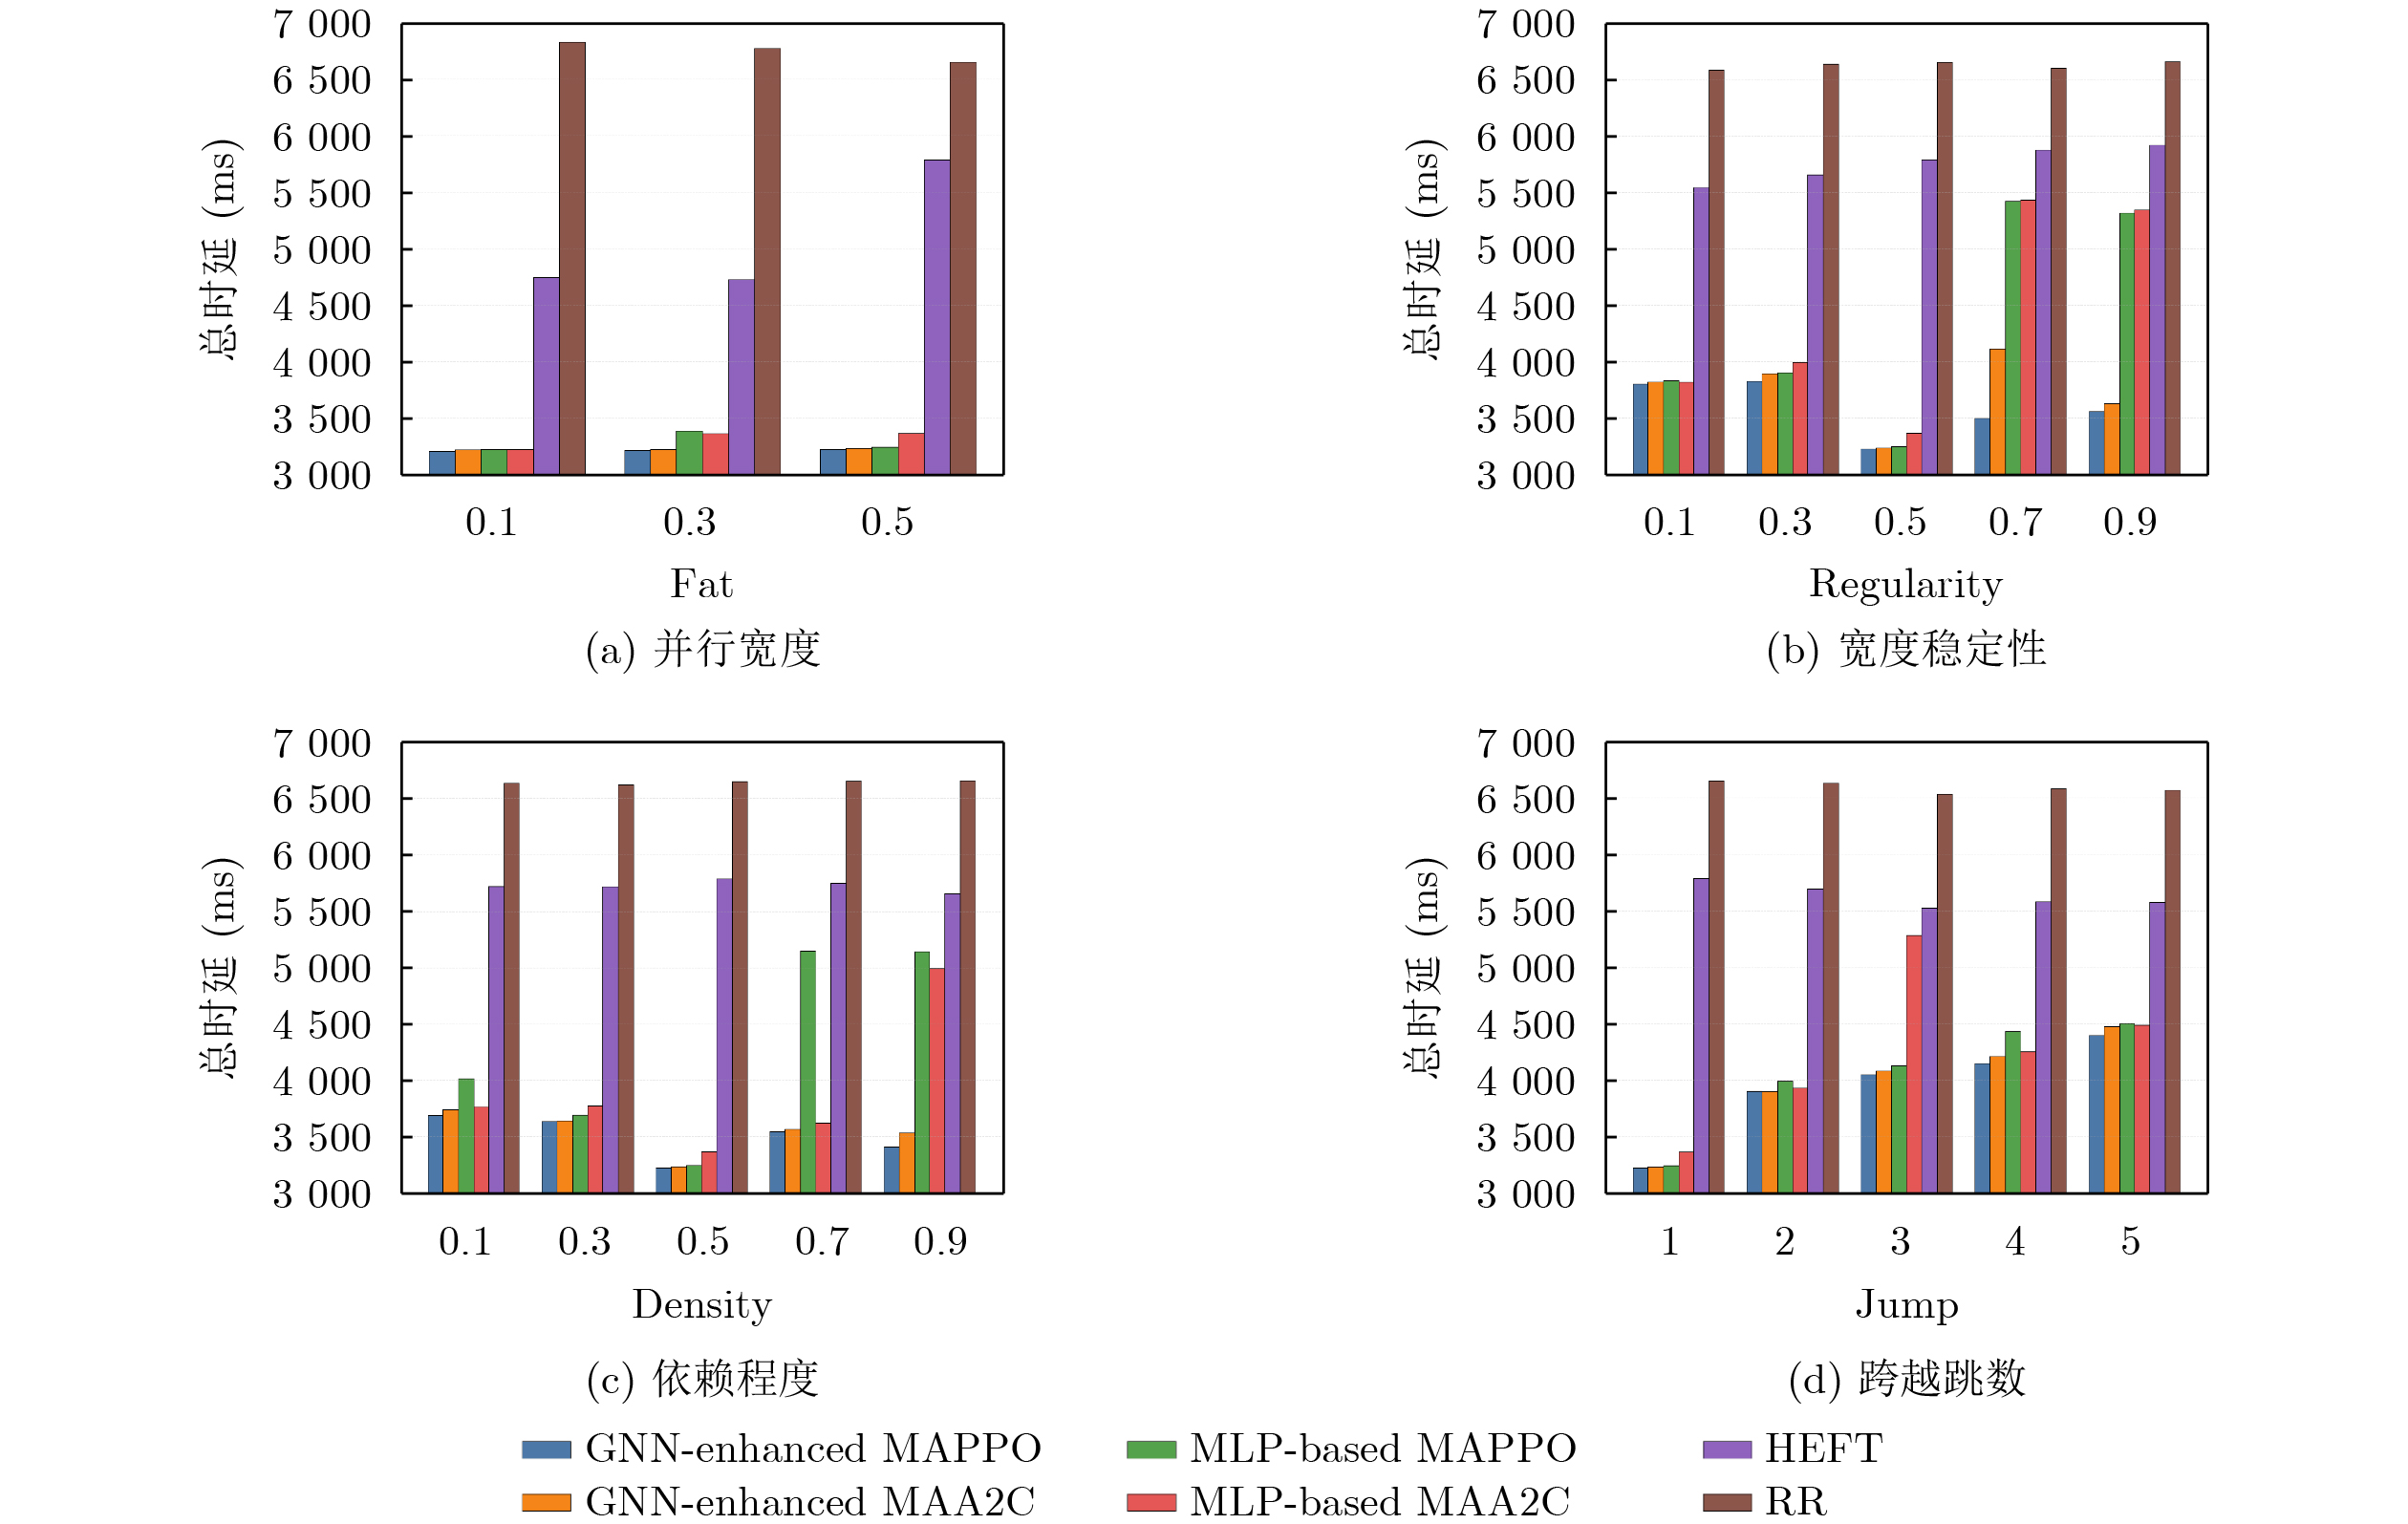
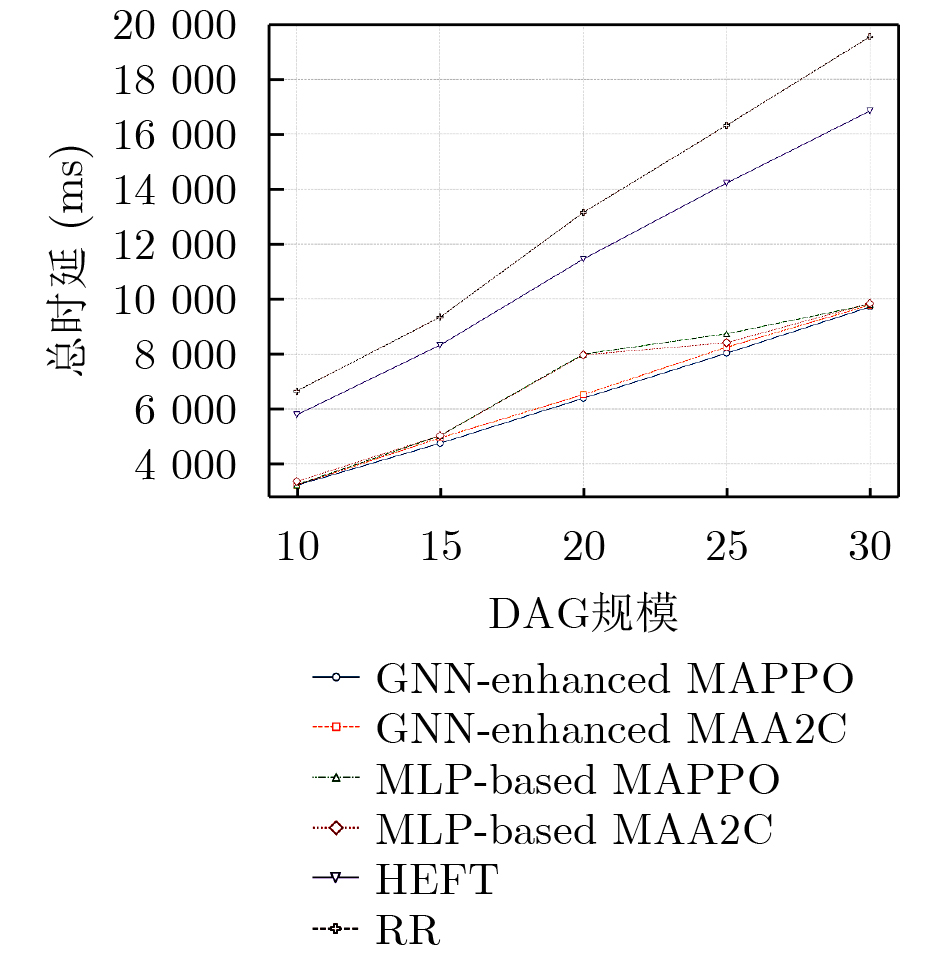
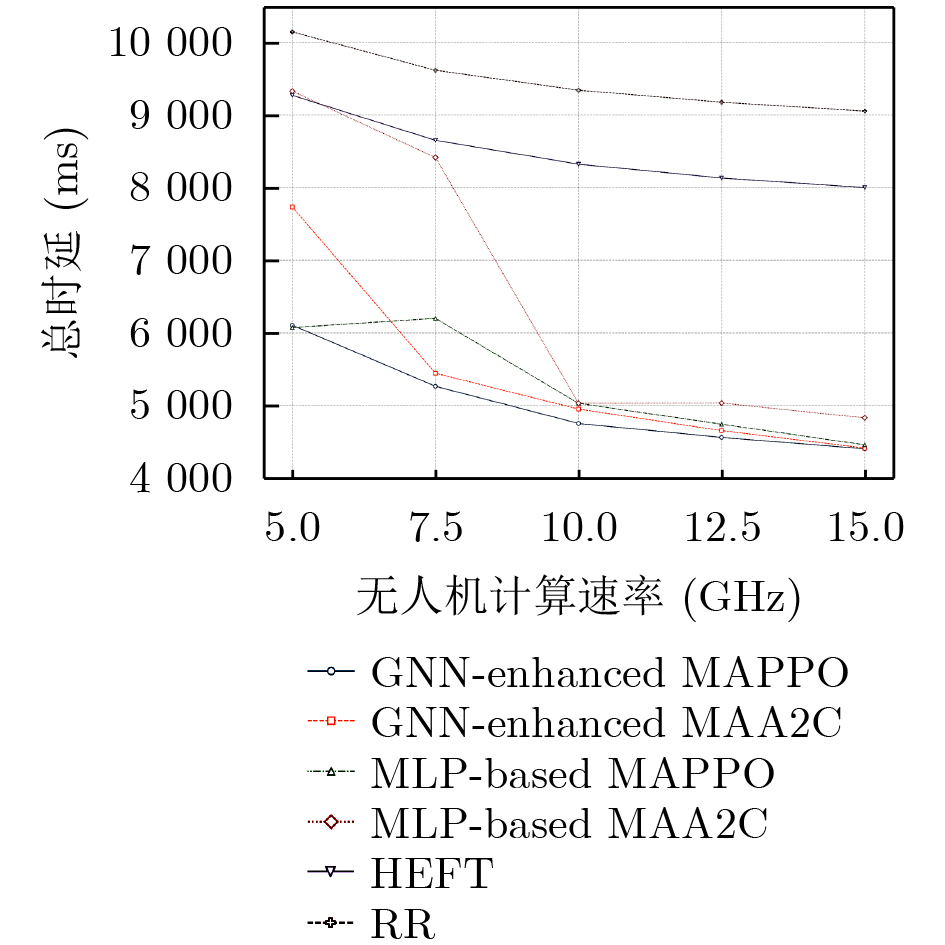
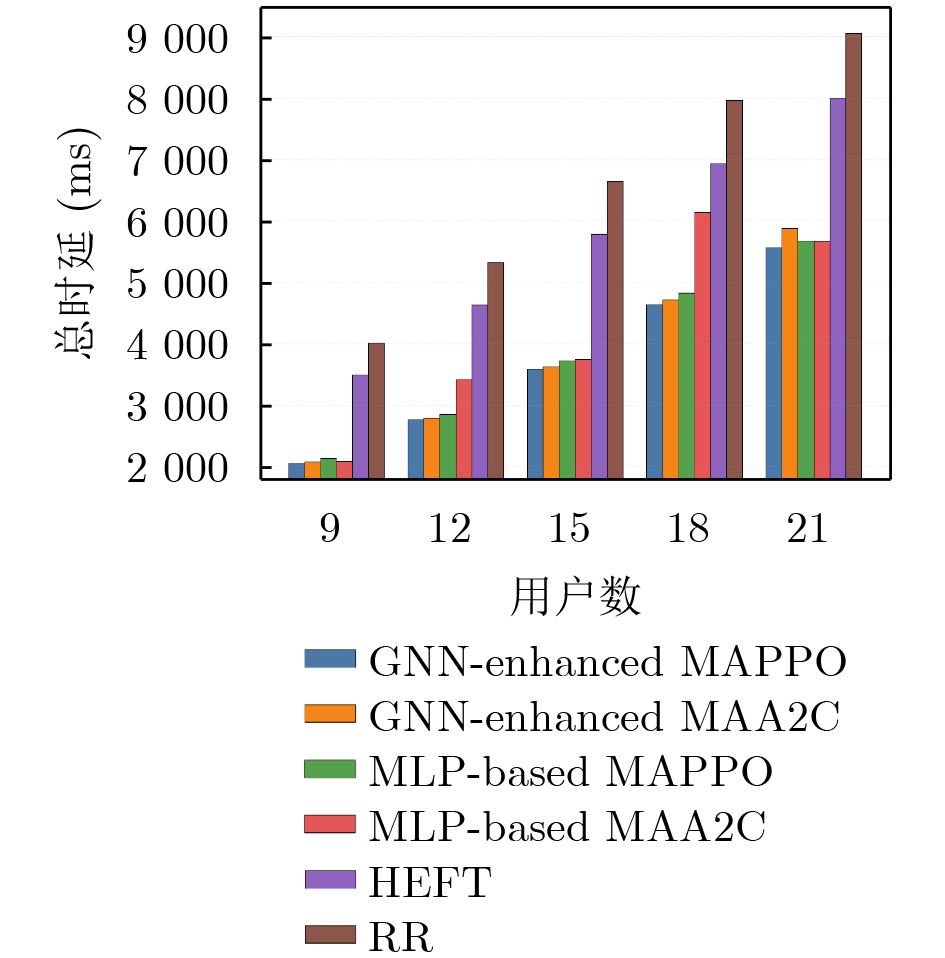
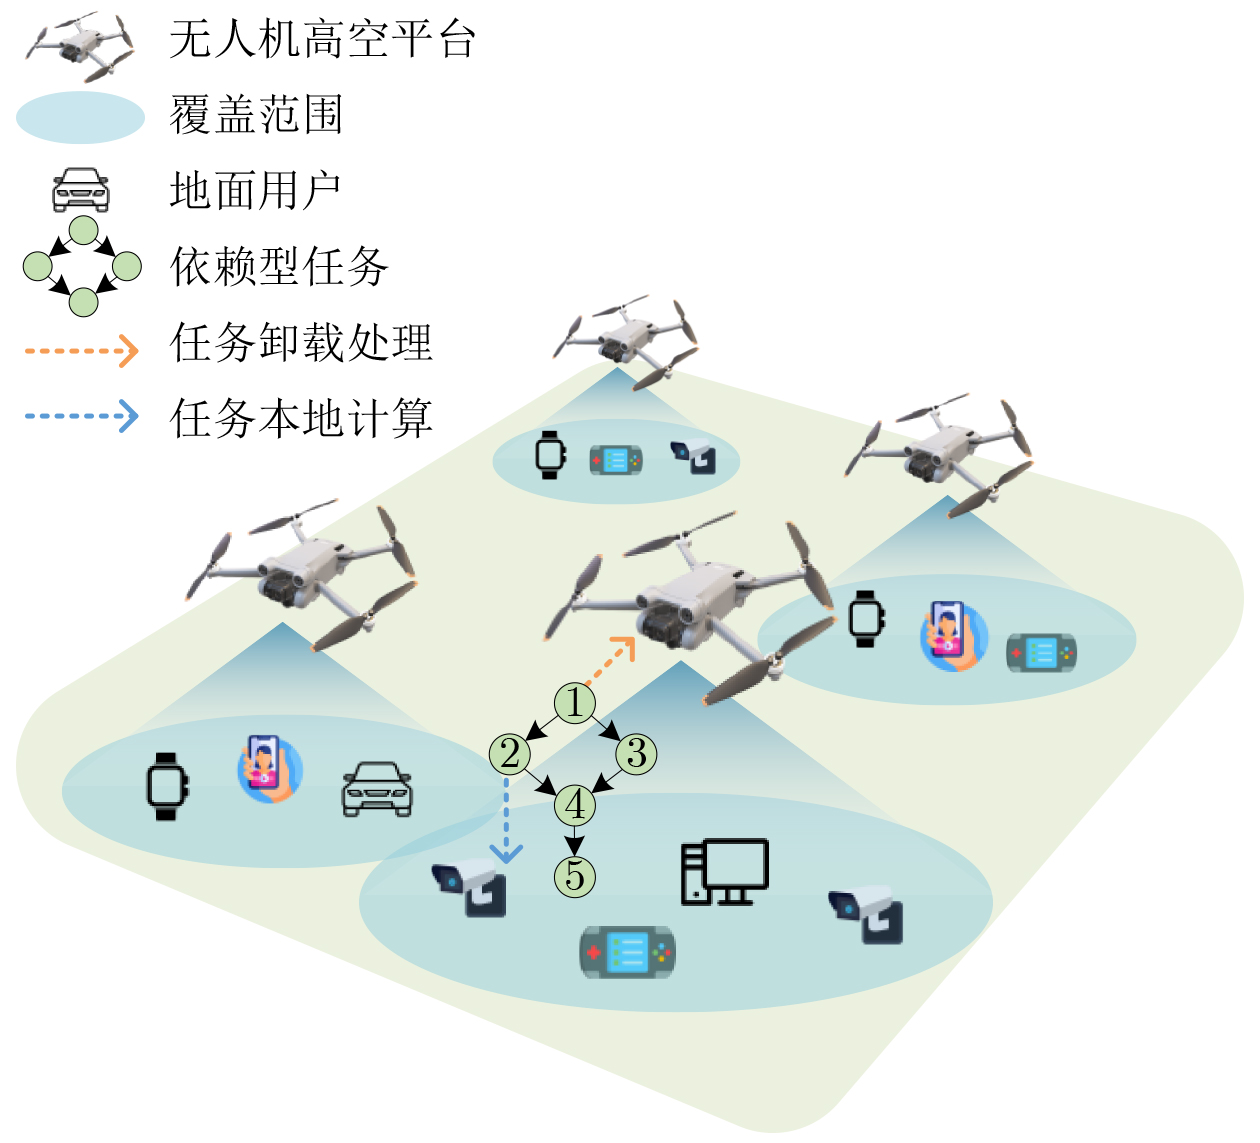
Objective The integration of edge computing servers into unmanned aerial vehicle (UAV) has been witnessed a promising application paradigm, which can provide extensive coverage and computation services for complex edge intelligence applications in the Internet of Things (IoT). In this paper, a UAV-assisted mobile edge computing (MEC) system with task graphs is investigated. To address the mutual constraints among computation offloading decisions and low efficiency in sequential task execution caused by graph-structured features of edge intelligence tasks, a joint optimization strategy for computation offloading and power control for task graphs is proposed. The objective is to reduce the total task completion delay while considering user energy budget constraints and the precedence relationships among subtasks. Methods The intelligent applications are modeled as directed acyclic graph (DAG) tasks, where nodes represent subtasks and edges represent precedence constraints. Based on this task model, a joint optimization problem is formulated by considering DAG dependency constraints, computation offloading decision, local and edge computing processes, and user-side energy budgets. Since the execution of DAG tasks is event-driven and the decision intervals are not fixed, the problem is further modeled as a cooperative multi-agent semi-Markov decision process. To solve the problem, a graph-structure-enhanced multi-agent proximal policy optimization algorithm is proposed. The algorithm uses a graph neural network to extract topology-aware features from DAG tasks and adopts a centralized training and decentralized execution framework. In this framework, each user agent makes decisions based on local observations, while the centralized critic uses shared graph information during training to improve collaborative learning. The learned policy jointly determines task execution order, offloading decision, and transmit power. Results and Discussions Simulation results show that the proposed algorithm achieves lower total system delay than typical learning-based algorithms and heuristic methods. Compared with MLP-based methods, the graph-enhanced schemes better capture the precedence relationships and task progression states in DAG tasks, which improves scheduling performance. Compared with the MAA2C-based method, the proposed MAPPO-based method shows better overall convergence and total system delay. The results under different DAG structures, task scales, UAV computing rates and user numbers further demonstrate that the proposed method has good adaptability to task topology variations and system parameter changes. Conclusions The proposed graph-structure-enhanced MAPPO algorithm provides an effective solution for dependent task offloading and resource control in UAV-assisted MEC systems. By jointly considering task topology, computation offloading decision, communication and computing resources, and user energy constraints, the method improves collaborative scheduling performance under multi-user multi-UAV settings. The study shows that explicitly modeling DAG dependencies and embedding graph representations into multi-agent reinforcement learning can effectively enhance delay optimization and task-structure adaptability for complex edge intelligent applications. -
表 1 UAV协助MEC系统任务图计算卸载方法对比
文献 应用场景 任务
类型任务状态表示 多智能体协同 CTDE框架 联合决策动作 [14] 单UAV协助MEC 任务图 向量化
表示是 否 UAV轨迹规划、任务调度、
计算卸载决策[15] 单UAV协助MEC 任务图 向量化
表示否 否 UAV轨迹规划、任务调度、服务部署 [16] 多UAV协助MEC 任务图 图结构化表示 否 否 无人机部署、用户关联、
计算卸载决策[17] 多UAV协助MEC 任务图 向量化
表示否 否 任务优先级排序、计算卸载决策 [18] 车辆-UAV-云服务器三层计算架构 任务图 向量化
表示是 是 计算卸载决策 [19] 终端-UAV-微云三层计算架构 任务图 向量化
表示否 否 缓存、计算卸载决策、带宽分配 本文工作 多UAV协助MEC 任务图 图结构化表示 是 是 计算卸载决策、任务调度、功率控制  下载: 导出CSV
1 图结构增强的MAPPO算法训练过程
输入:Actor参数$ \theta $,Critic参数$ \phi $,训练回合数$ {N}_{\text{epi}} $,最大决策
步数$ K $输出:训练后的策略参数$ {\theta }^{*} $ 1:for $ e=1,2,\cdots ,{N}_{\text{epi}} $ do 2: 重置环境并清空经验$ \mathcal{D} $ 3: for $ k=1,2,\cdots ,K $ do 4: for 每个活跃用户$ n\in \mathcal{N}_{k}^{\text{act}} $ do 5: 构造局部图观测$ o_{n}^{k} $,由Actor采样动作$ a_{n}^{k} $ 6: end for 7: 构造共享图观测$ {\tilde{s}}_{k} $,由Critic计算$ {V}_{\phi }({\tilde{s}}_{k}) $ 8: 执行联合动作$ {\mathbf{a}}_{k} $,获得奖励$ {r}_{k} $和终止标志$ {d}_{k} $ 9: 将当前转移样本存入$ \mathcal{D} $ 10: if $ {d}_{k}=1 $ then 11: break 12: end if 13: end for 14: 基于$ \mathcal{D} $计算回报$ {\hat{R}}_{k} $和优势估计$ {\hat{A}}_{k} $ 15: 按小批量样本最小化价值损失并最大化PPO裁剪目标,
更新$ \phi $和$ \theta $16:end for 17:return $ {\theta }^{*} $
下载: 导出CSV
-
[1] YANG Ning, CHEN Shuo, ZHANG Haijun, et al. Beyond the edge: An advanced exploration of reinforcement learning for mobile edge computing, its applications, and future research trajectories[J]. IEEE Communications Surveys & Tutorials, 2025, 27(1): 546–594. doi: 10.1109/COMST.2024.3405075. [2] 桓海盛, 赵鹏, 陈诺, 等. 移动边缘计算卸载技术研究综述[J]. 计算机科学, 2026, 53(2): 367–378. doi: 10.11896/jsjkx.250100058.HUAN Haisheng, ZHAO Peng, CHEN Nuo, et al. Review of offloading technologies research in mobile edge computing[J]. Computer Science, 2026, 53(2): 367–378. doi: 10.11896/jsjkx.250100058. [3] GOUDARZI S, SOLEYMANI S A, WANG Wenwu, et al. UAV-enabled mobile edge computing for resource allocation using cooperative evolutionary computation[J]. IEEE Transactions on Aerospace and Electronic Systems, 2023, 59(5): 5134–5147. doi: 10.1109/TAES.2023.3251967. [4] YUAN Haitao, WANG Meijia, BI Jing, et al. Cost-efficient task offloading in mobile edge computing with layered unmanned aerial vehicles[J]. IEEE Internet of Things Journal, 2024, 11(19): 30496–30509. doi: 10.1109/JIOT.2024.3408216. [5] KUANG Zhufang, PAN Yihui, YANG Fan, et al. Joint task offloading scheduling and resource allocation in air–ground cooperation UAV-enabled mobile edge computing[J]. IEEE Transactions on Vehicular Technology, 2024, 73(4): 5796–5807. doi: 10.1109/TVT.2023.3334143. [6] WANG Bowen, SUN Yanjing, JUNG H, et al. Digital twin-enabled computation offloading in UAV-assisted MEC emergency networks[J]. IEEE Wireless Communications Letters, 2023, 12(9): 1588–1592. doi: 10.1109/LWC.2023.3283912. [7] 谭国平, 易文雄, 周思源, 等. 无人机辅助MEC车辆任务卸载与功率控制近端策略优化算法[J]. 电子与信息学报, 2024, 46(6): 2361–2371. doi: 10.11999/JEIT230770.TAN Guoping, Yi Wenxiong, ZHOU Siyuan, et al. Proximal policy optimization algorithm for UAV-assisted MEC vehicle task offloading and power control[J]. Journal of Electronics & Information Technology, 2024, 46(6): 2361–2371. doi: 10.11999/JEIT230770. [8] 闫莉, 王俊凯, 方旭明, 等. 无人机辅助的铁路无线传感网智能数据收集与计算卸载方法[J]. 电子与信息学报, 2025, 47(11): 4153–4165. doi: 10.11999/JEIT250340.YAN Li, WANG Junkai, FANG Xuming, et al. UAV-assisted intelligent data collection and computation offloading for railway wireless sensor networks[J]. Journal of Electronics & Information Technology, 2025, 47(11): 4153–4165. doi: 10.11999/JEIT250340. [9] XU Wenlong, ZHANG Tiankui, MU Xidong, et al. Trajectory planning and resource allocation for multi-UAV cooperative computation[J]. IEEE Transactions on Communications, 2024, 72(7): 4305–4318. doi: 10.1109/TCOMM.2024.3361536. [10] YAN Ming, YU Peiying, CHEN Junfeng, et al. Dynamic computation offloading optimization based on meta-reinforcement learning in UAV-assisted MEC networks[J]. IEEE Internet of Things Journal, 2026, 13(11): 23615–23627. doi: 10.1109/JIOT.2026.3670318. [11] ZHOU Xiaobo, GE Shuxin, LIU Pengbo, et al. DAG-based dependent tasks offloading in MEC-enabled IoT with soft cooperation[J]. IEEE Transactions on Mobile Computing, 2024, 23(6): 6908–6920. doi: 10.1109/TMC.2023.3328333. [12] LIU Zhang, HUANG Lianfen, GAO Zhibin, et al. GA-DRL: Graph neural network-augmented deep reinforcement learning for DAG task scheduling over dynamic vehicular clouds[J]. IEEE Transactions on Network and Service Management, 2024, 21(4): 4226–4242. doi: 10.1109/TNSM.2024.3387707. [13] MACK J, ARDA S E, OGRAS U Y, et al. Performant, multi-objective scheduling of highly interleaved task graphs on heterogeneous system on chip devices[J]. IEEE Transactions on Parallel and Distributed Systems, 2022, 33(9): 2148–2162. doi: 10.1109/TPDS.2021.3135876. [14] ZHENG Chunxiang, PAN Kai, DONG Jiadong, et al. Multi-agent collaborative optimization of UAV trajectory and latency-aware DAG task offloading in UAV-assisted MEC[J]. IEEE Access, 2024, 12: 42521–42534. doi: 10.1109/ACCESS.2024.3378512. [15] WEI Xianglin, CAI Lingfeng, WEI Nan, et al. Joint UAV trajectory planning, DAG task scheduling, and service function deployment based on DRL in UAV-empowered edge computing[J]. IEEE Internet of Things Journal, 2023, 10(14): 12826–12838. doi: 10.1109/JIOT.2023.3257291. [16] ZHAN Cheng, LIU Wei, SONG Kaifeng, et al. Joint UAV placement and dependent task offloading in multi-UAV MEC networks: A graph attention enhanced DRL approach[J]. IEEE Transactions on Mobile Computing, 2026, 25(4): 5285–5301. doi: 10.1109/TMC.2025.3628608. [17] WANG Ji, CHEN Peipei, ZHANG Miao, et al. Dynamic offloading for deadline-aware dependent tasks in UAV-empowered multi-access edge computing[J]. IEEE Transactions on Vehicular Technology, 2026, 75(8): 18192–18205. doi: 10.1109/TVT.2026.3676992. [18] SHEN Si, SHEN Guojiang, DAI Zhehao, et al. Asynchronous federated deep-reinforcement-learning-based dependency task offloading for UAV-assisted vehicular networks[J]. IEEE Internet of Things Journal, 2024, 11(19): 31561–31574. doi: 10.1109/JIOT.2024.3418488. [19] 王义君, 王雅出, SHAHD B, 等. 无人机辅助动态权重边缘计算卸载策略研究[J]. 电子与信息学报, 2026, 48(7): 3071–3083. doi: 10.11999/JEIT260054.WANG Yijun, WANG Yachu, SHAHD B, et al. Research on UAV-assisted dynamic-weight edge computing offloading strategy[J]. Journal of Electronics & Information Technology, 2026, 48(7): 3071–3083. doi: 10.11999/JEIT260054. [20] KHORAMNEJAD F, SYED A, KENNEDY W S, et al. Energy and delay aware general task dependent offloading in UAV-aided smart farms[J]. IEEE Transactions on Network and Service Management, 2024, 21(5): 5033–5048. doi: 10.1109/TNSM.2024.3391664. [21] SUTER F. DAGGEN: A synthetic task graph generator[EB/OL]. https://github.com/frs69wq/daggen, 2025. [22] DENG Xiaoheng, YANG Haoyu, ZHANG Jingjing, et al. Task offloading in internet of vehicles: A DRL-based approach with representation learning for DAG scheduling[J]. IEEE Transactions on Mobile Computing, 2025, 24(6): 5045–5060. doi: 10.1109/TMC.2025.3531887. -

 下载:

图(8) / 表(2)
计量
- 文章访问数: 12
- HTML全文浏览量: 3
- PDF下载量: 0
- 被引次数: 0
